Calder Robbins
Biomechanics & Robotics Researcher
Design, control, and simulation of wearable robots for human mobility
About Me
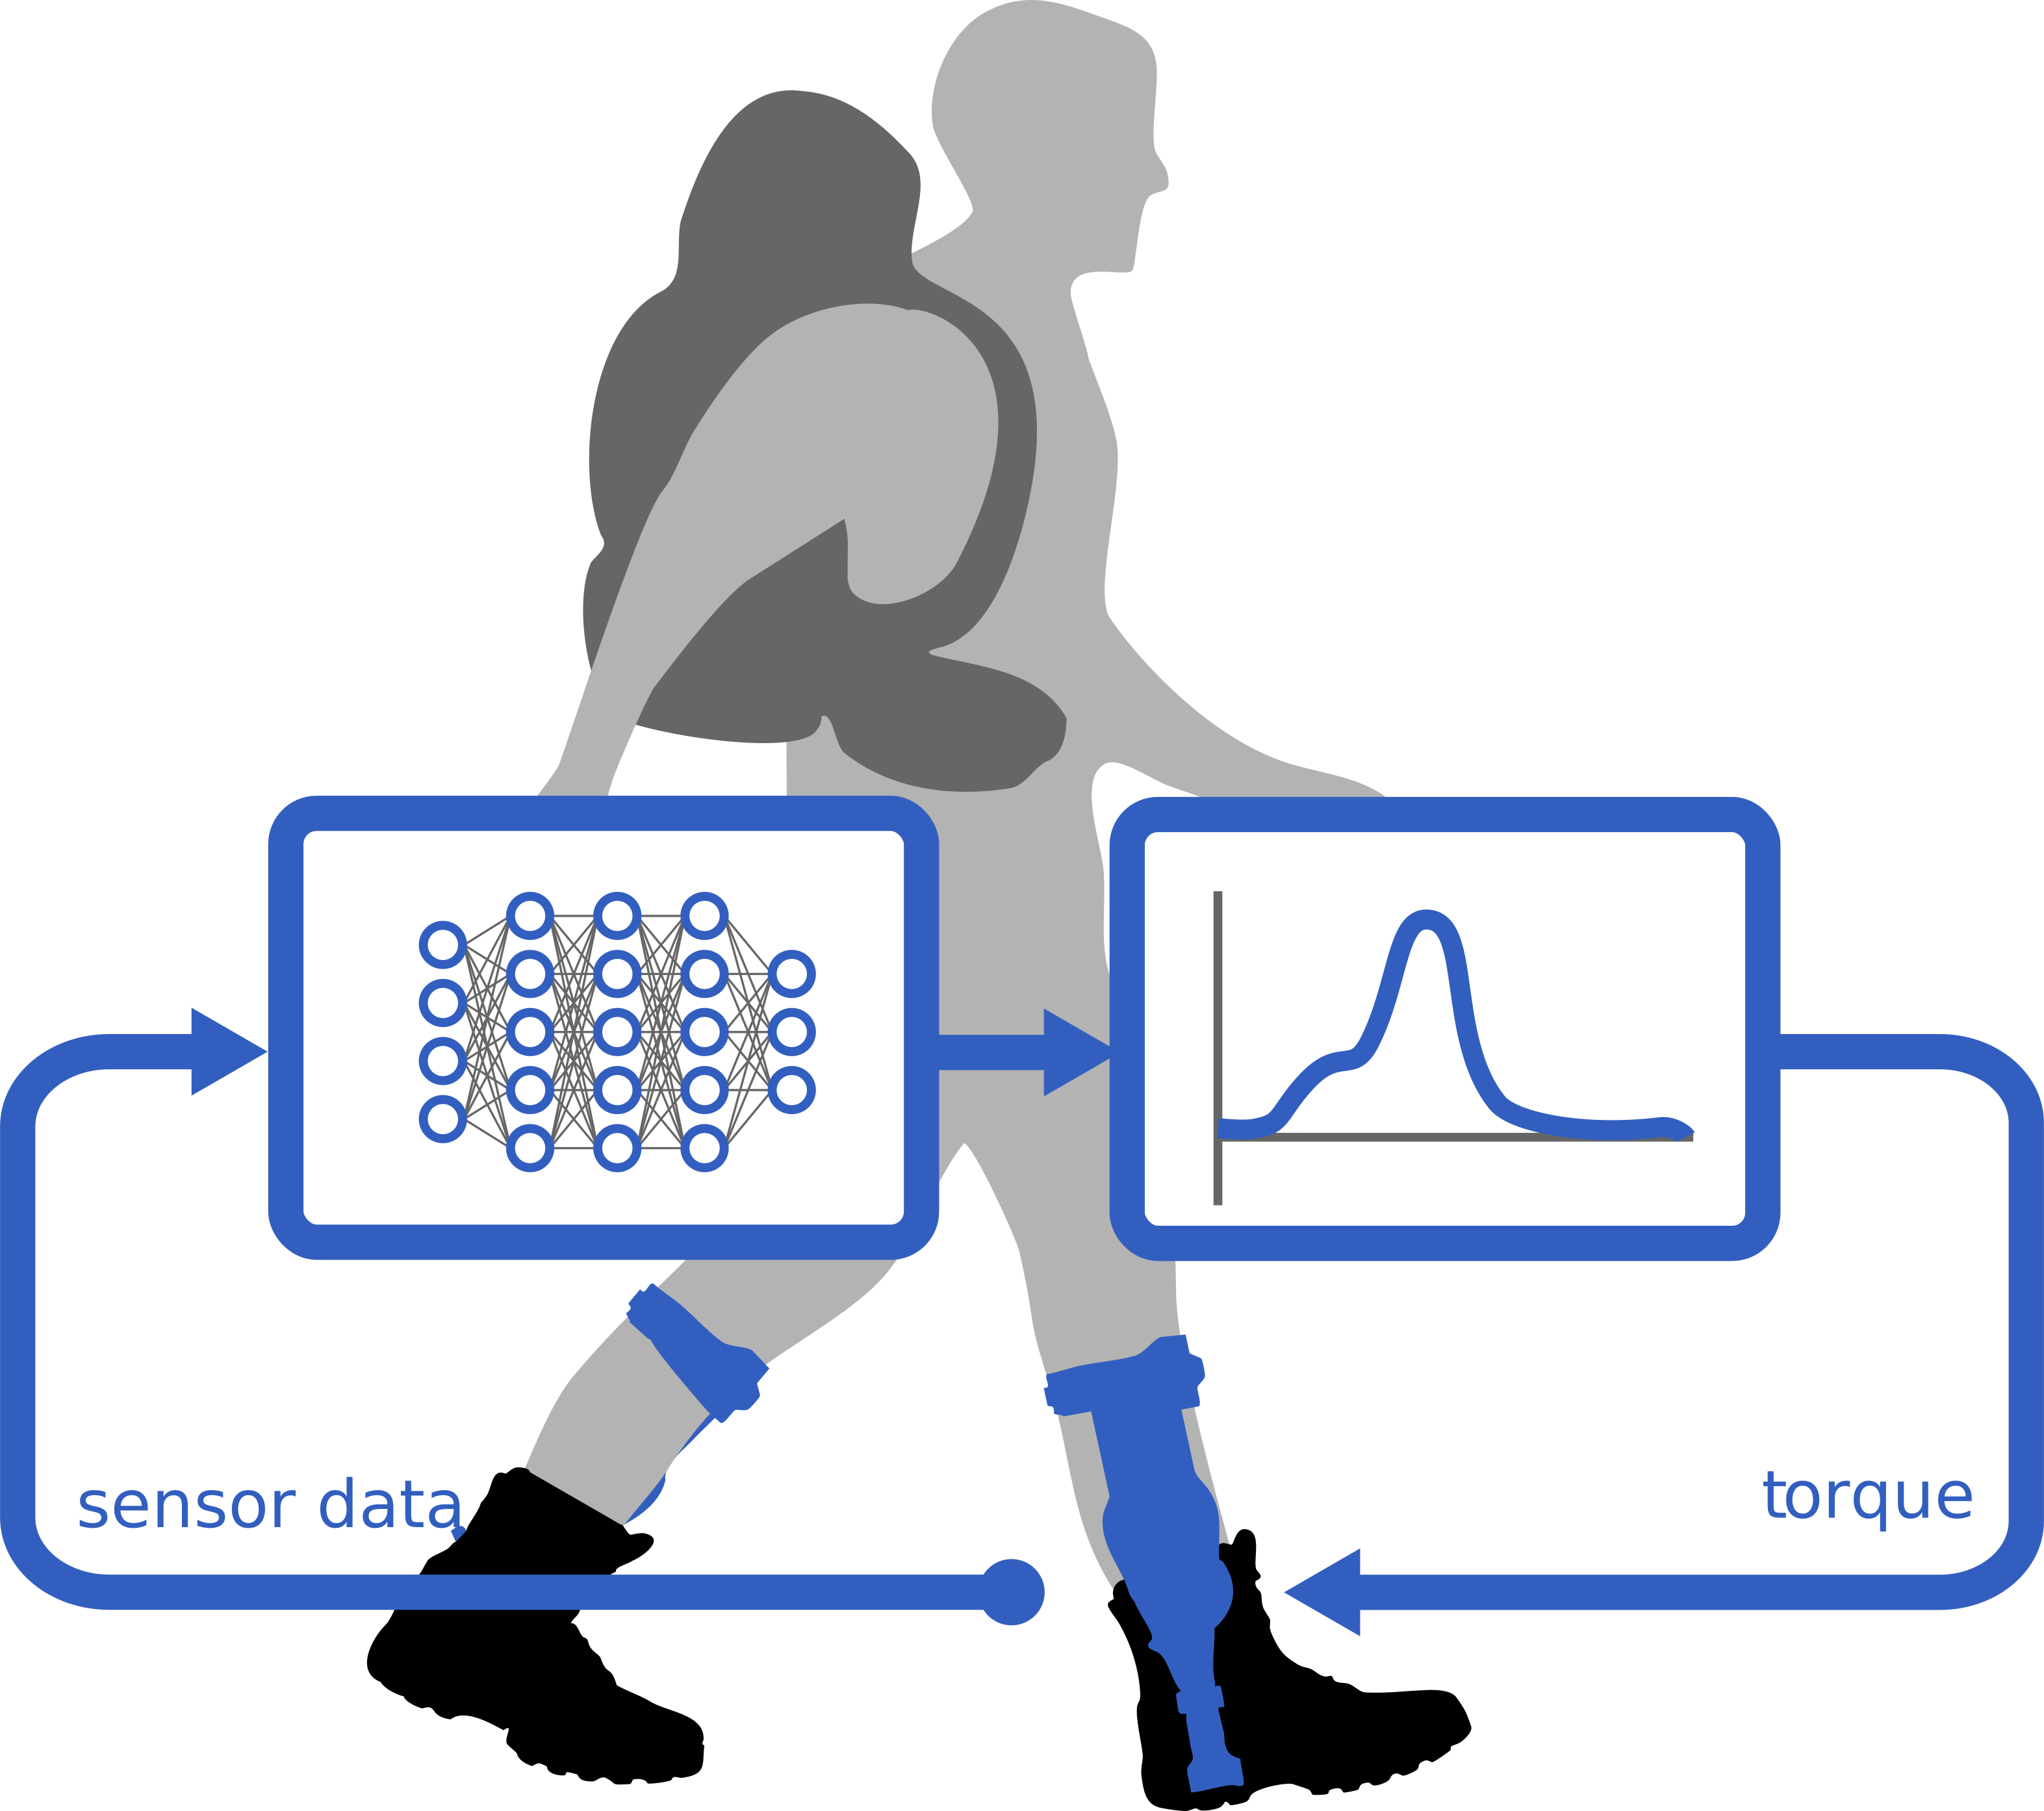
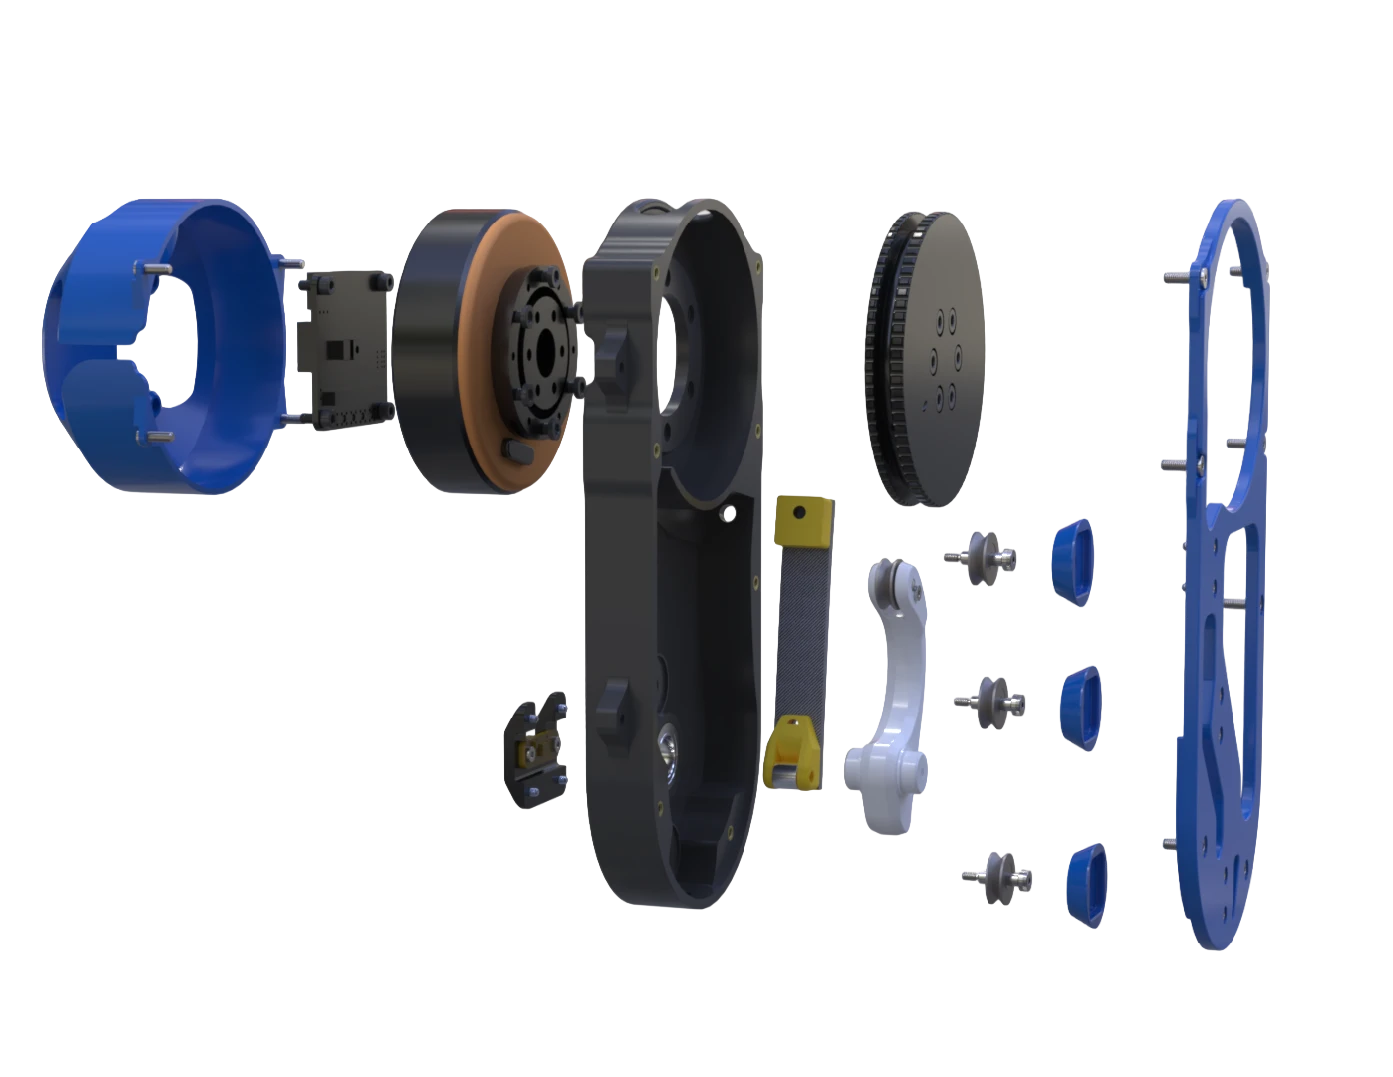
I'm a graduate researcher in Northeastern University's NeuMove Laboratory, advised by Prof. Seungmoon Song, where my work focuses on the design, control, and simulation of wearable robotics. My thesis centers on advancing ankle exoskeleton design and control, combining hardware development, musculoskeletal modeling, and ML control frameworks.
My path to wearable robotics started in biomechanics. I earned my B.S. in Biomedical Engineering (2023) and M.S. in Mechanical Engineering (2024) at UMass Amherst, studying performance running footwear with Prof. Wouter Hoogkamer and developing variable stiffness footwear with Prof. Meghan Huber.
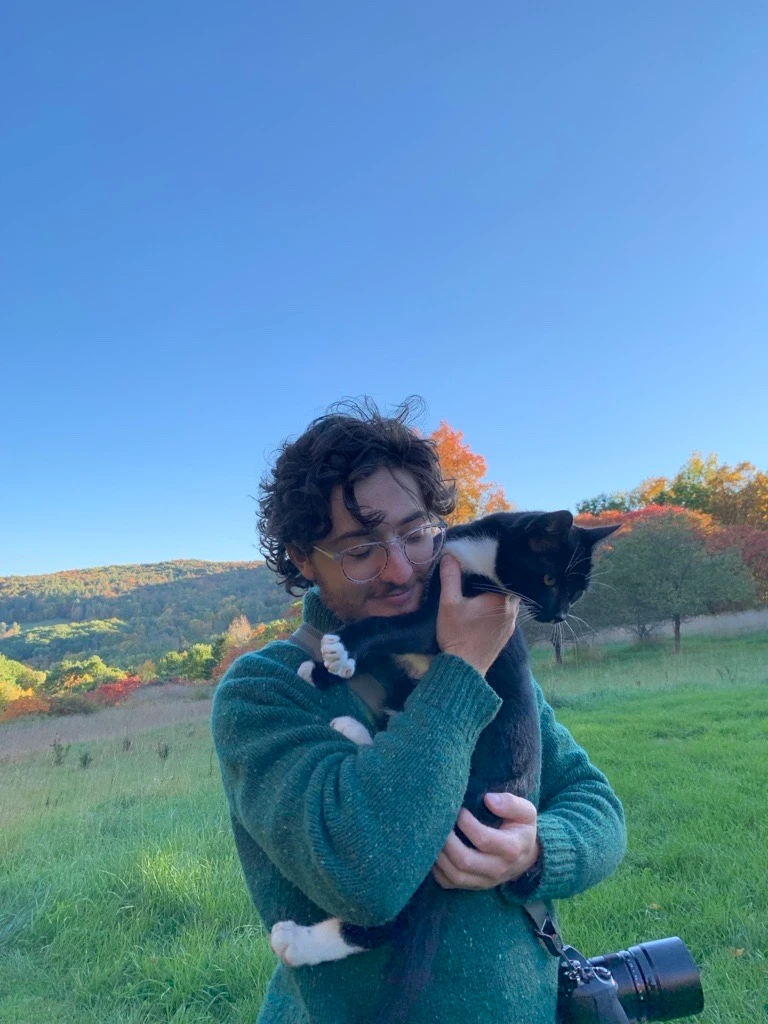
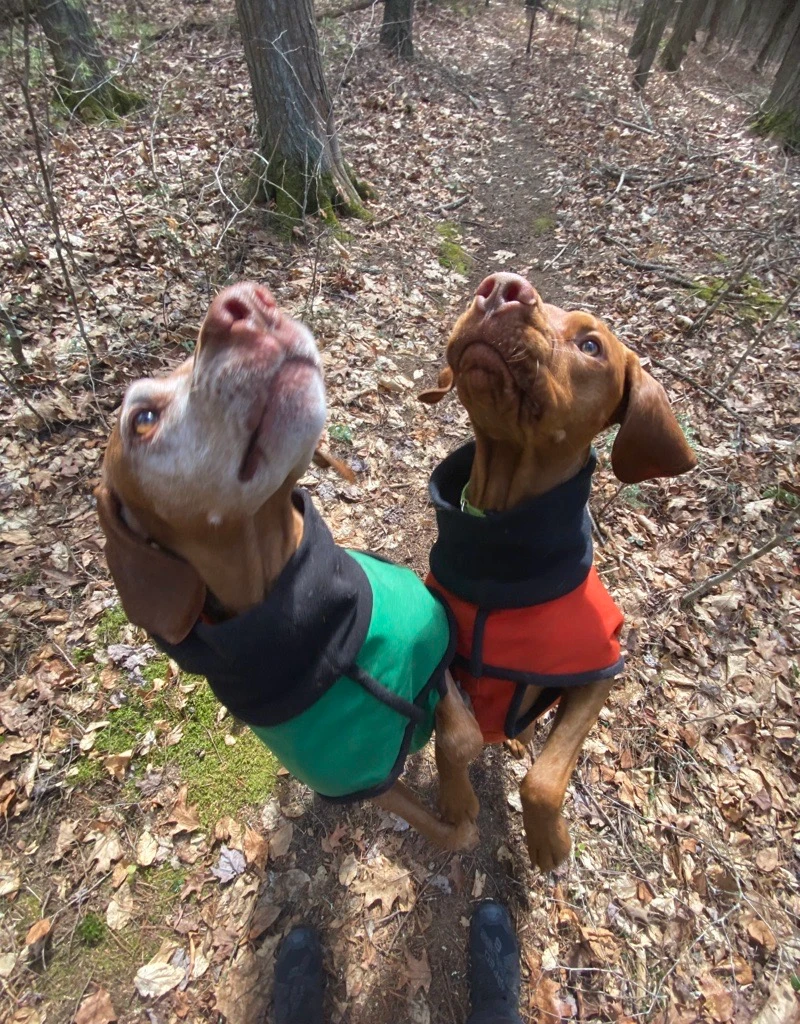
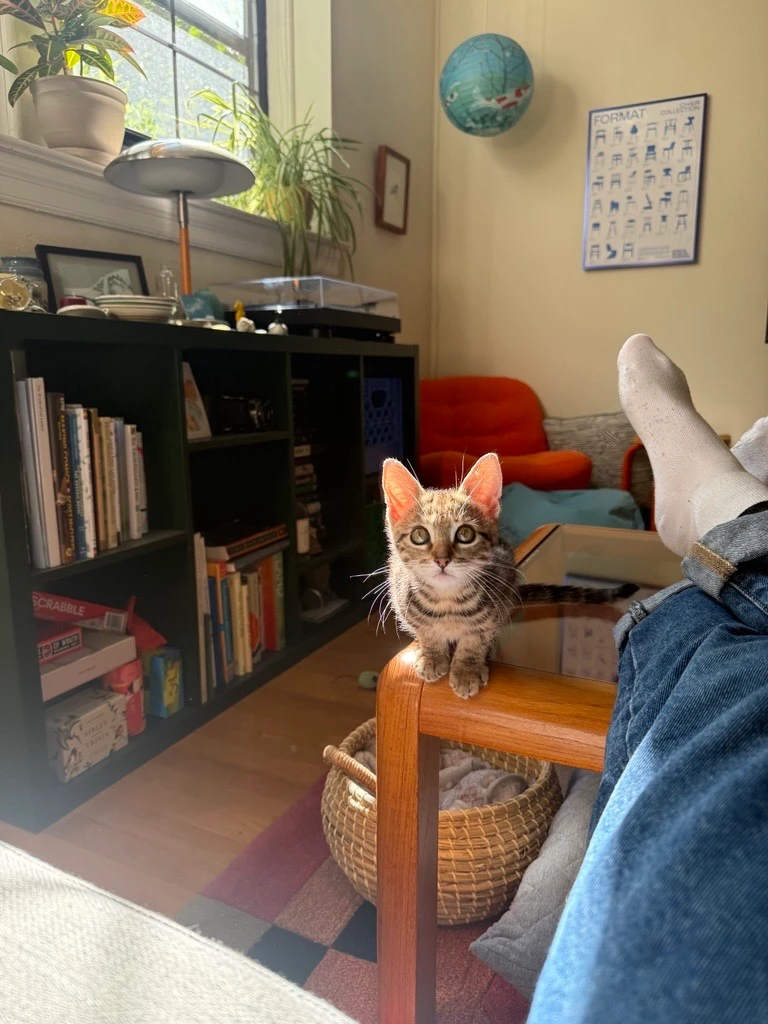
Outside the lab, I'm an avid wildlife photographer and spend as much time as I can biking, hiking with my two dogs, or listening to records with my cat.
Programming
- Python
- MATLAB
Modeling
- SolidWorks
- MuJoCo
Experimental
- Motion Capture
- EMG
- OpenSim
- MyoSuite
Design
- Adobe Creative Suite